Building a Skydroid Mission Stack: RTK, Gimbal and Avionics in One Aircraft
The integration view of a Skydroid aircraft: link first, then RTK base station, gimbal payload and S3 or S3-A autopilot, with a worked survey build and the mistakes we see.
The integration view of a Skydroid aircraft: link first, then RTK base station, gimbal payload and S3 or S3-A autopilot, with a worked survey build and the mistakes we see.
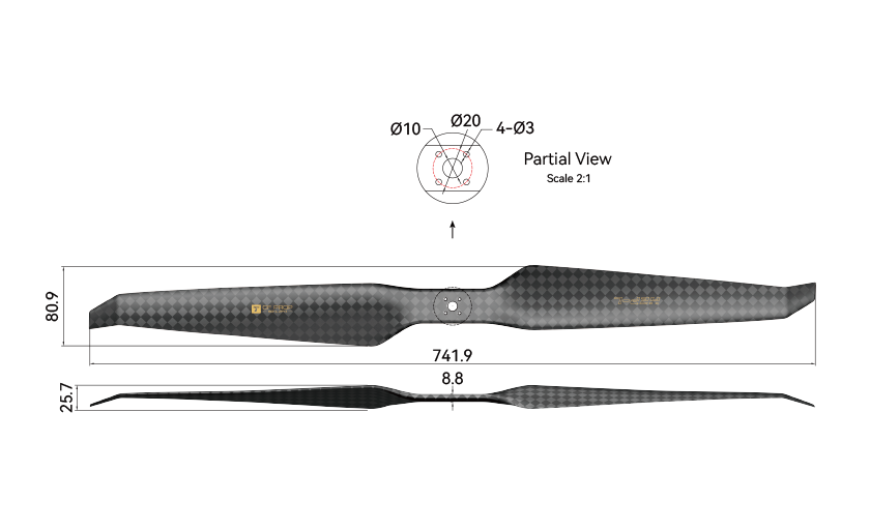
How to size a UAV ESC against real motor current, why the propeller has to be fixed before the ESC, and how FOC, telemetry, HEP-L props and quick-release adapters fit together.
Why drone links drop, what relays, repeaters and antennas each actually do, how video transmission boxes fit in, and how to pick the right fix for terrain and range.

What is inside a matched UAV propulsion set, when it beats buying parts separately, how to size one, and which X-series, A10 or AirGear kit fits your airframe.
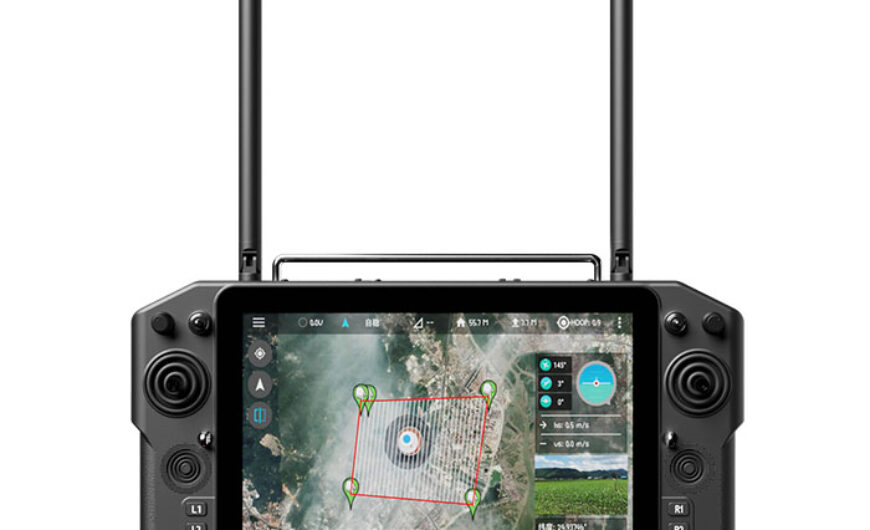
How to choose a Skydroid controller and video link by mission: entry G11 up to the G20 ground station, plus relays, antennas, RTK, gimbals and the S3 autopilot.
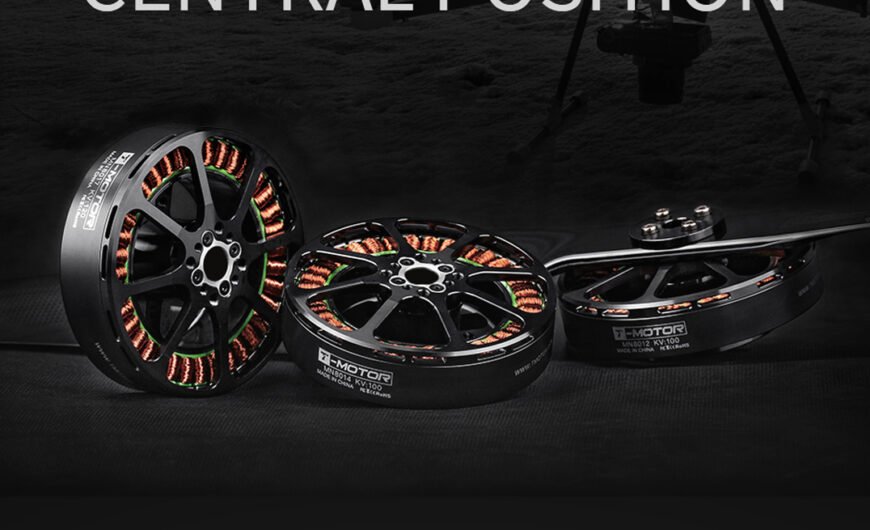
A working guide to UAV motor selection: start from all-up weight, read thrust tables at the hover point, then match the ESC and propeller. Includes the mistakes we correct most often.
0 items in the cart ($0.00)